Core project
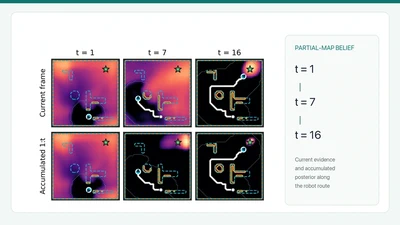
MAPLE-RF: Localization with Partial Maps
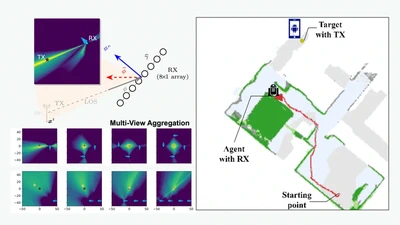
Efficient neural posterior inference for RF source localization while a robot has explored only part of its environment.
•
1 min read
Core project
Efficient neural posterior inference for RF source localization while a robot has explored only part of its environment.
Core project
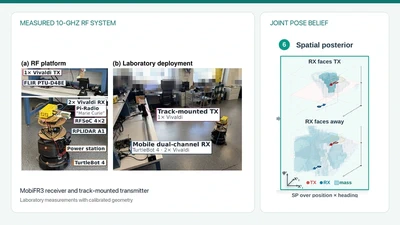
Multipath-guided joint posteriors over transmitter position and heading, calibrated from simulation and evaluated on a 10-GHz robotic RF testbed.
Mentored emerging direction
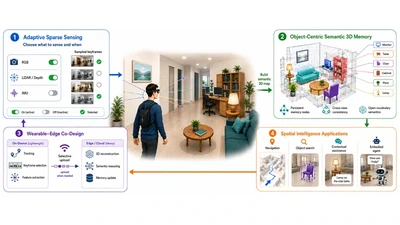
A mentored exploratory project on sparse RGB-D sensing, object memory, retrieval, and embodied spatial reasoning.
Secondary project
Ray-tracing digital-twin priors and physics-informed reinforcement learning for zero-shot indoor navigation.
Core project
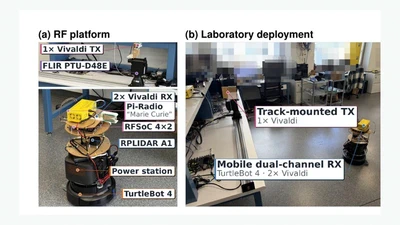
A 10-GHz robotic RF testbed connecting channel sounding, mobile sensing, localization, and SLAM-based navigation experiments.