Core project
MAPLE-RF: Localization with Partial Maps
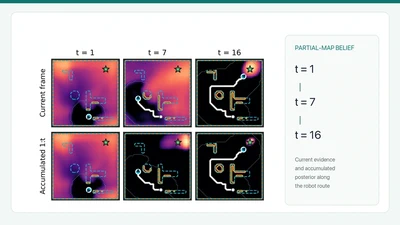
Efficient neural posterior inference for RF source localization while a robot has explored only part of its environment.
•
1 min read
Core project
Efficient neural posterior inference for RF source localization while a robot has explored only part of its environment.