Core project
MC-CLE: Full-Posterior Wireless Localization
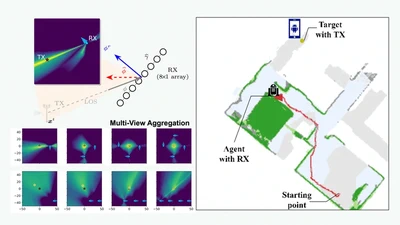
Candidate-wise neural likelihood estimation from sparse AoA and SNR measurements, preserving directional and multimodal uncertainty beyond point estimates.
Core and supporting projects spanning RF sensing, probabilistic localization, wireless digital twins, and autonomous systems.
Core project
Candidate-wise neural likelihood estimation from sparse AoA and SNR measurements, preserving directional and multimodal uncertainty beyond point estimates.
Core project
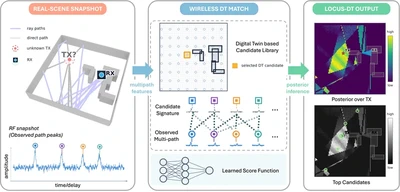
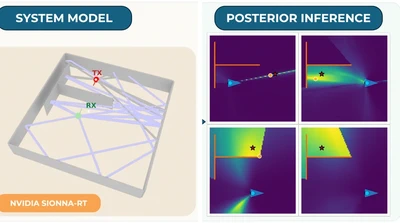
Observation-conditioned scoring of measured multipath against ray-traced location hypotheses for site-agnostic spatial posterior inference.
Core project
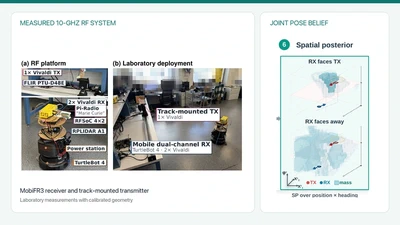
Multipath-guided joint posteriors over transmitter position and heading, calibrated from simulation and evaluated on a 10-GHz robotic RF testbed.
Core project
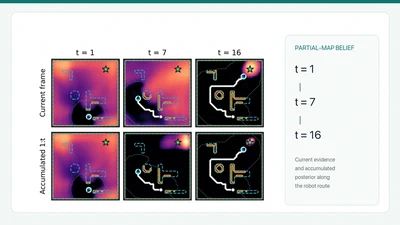
Efficient neural posterior inference for RF source localization while a robot has explored only part of its environment.
Core project
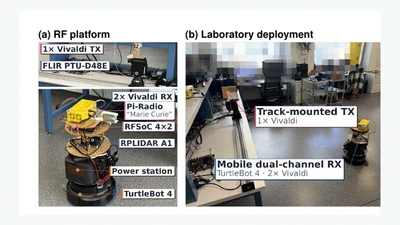
A 10-GHz robotic RF testbed connecting channel sounding, mobile sensing, localization, and SLAM-based navigation experiments.
Secondary project
Ray-tracing digital-twin priors and physics-informed reinforcement learning for zero-shot indoor navigation.
Secondary project
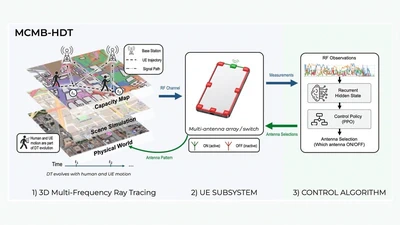
UE-centric multi-cell multi-band handset digital twins for closed-loop array, band, and rate prediction under mobility.
Mentored emerging direction
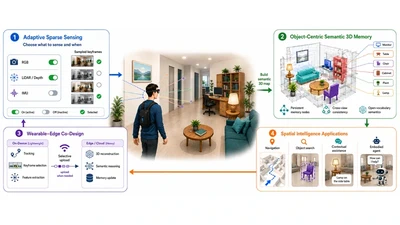
A mentored exploratory project on sparse RGB-D sensing, object memory, retrieval, and embodied spatial reasoning.